Publications

(* corresponding author)

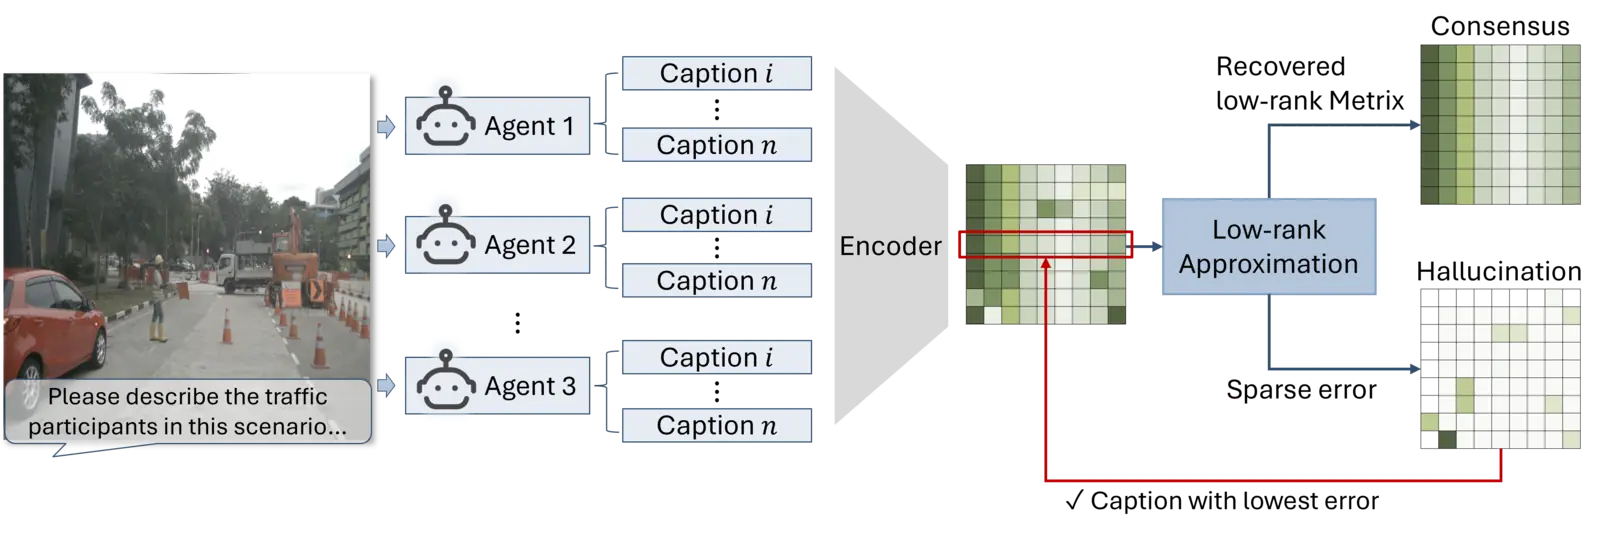
A Low-Rank Method for Vision Language Model Hallucination Mitigation in Autonomous Driving

A Low-Rank Method for Vision Language Model Hallucination Mitigation in Autonomous Driving

Long, K., Guo, J., Zhang, T., Yu, H., & Li, X.

Transportation Research Part C. 2026

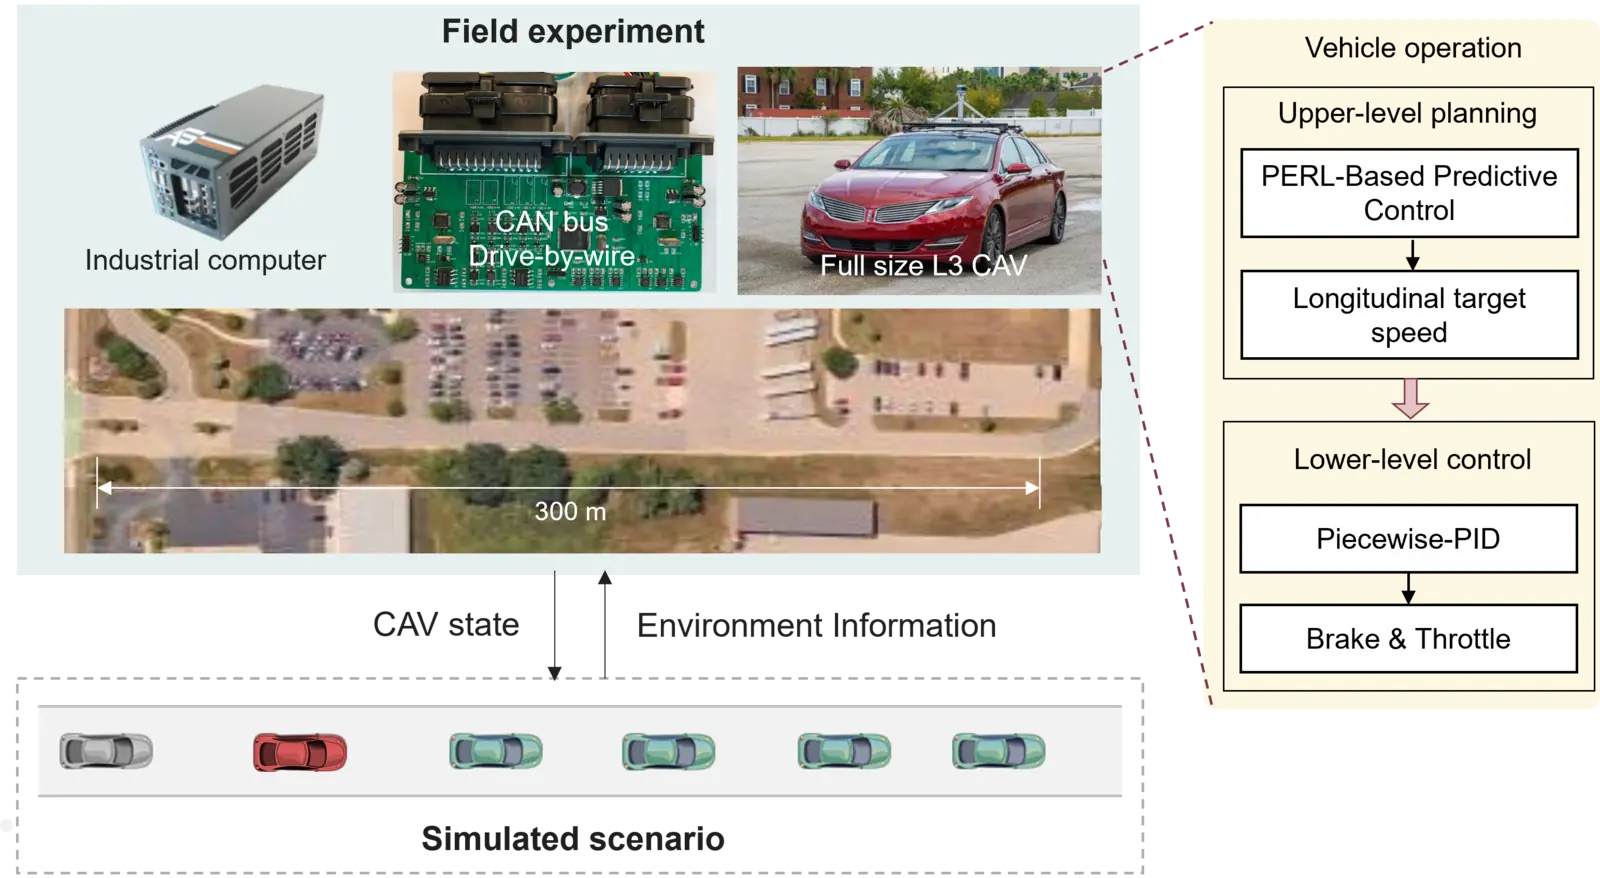
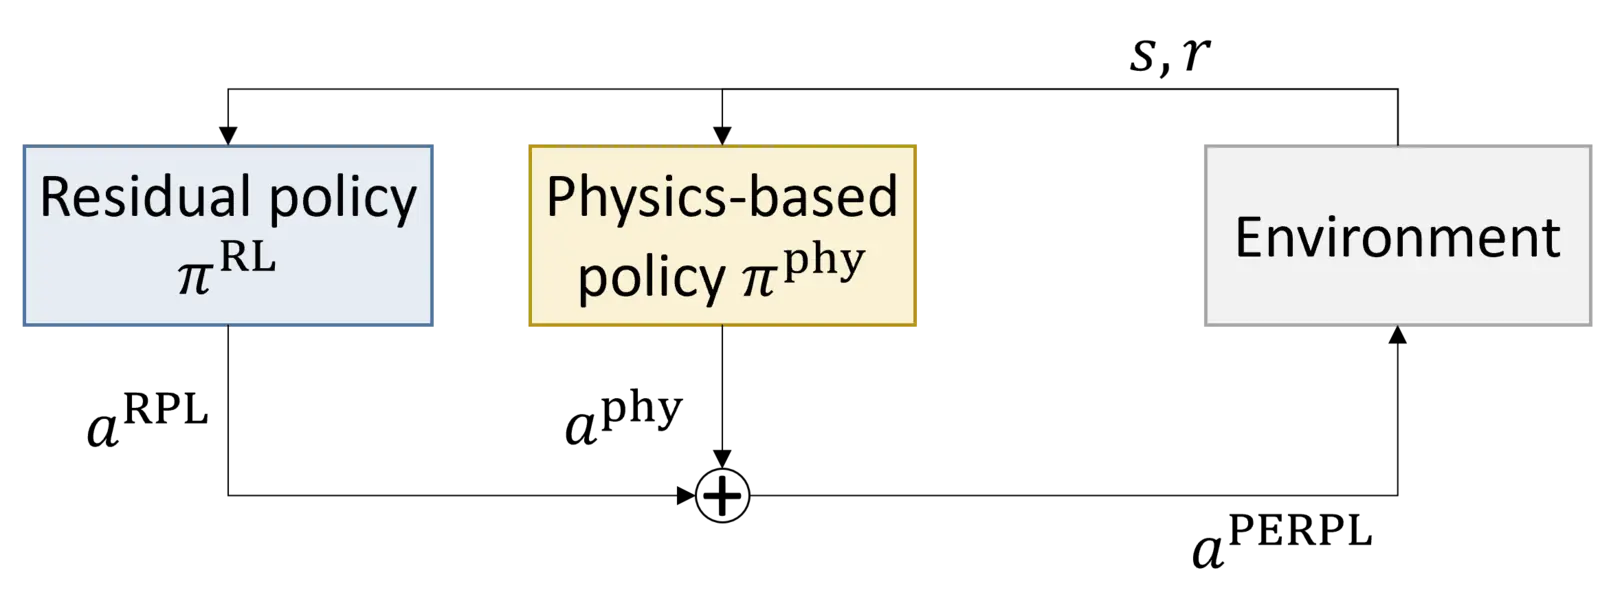
Physics Enhanced Residual Policy Learning (PERPL) for safety cruising in mixed traffic platooning under actuator and communication delay

Physics Enhanced Residual Policy Learning (PERPL) for safety cruising in mixed traffic platooning under actuator and communication delay

Long, K., Shi, H., Liang, S., & Li, X.

Transportation Research Part C. 2026

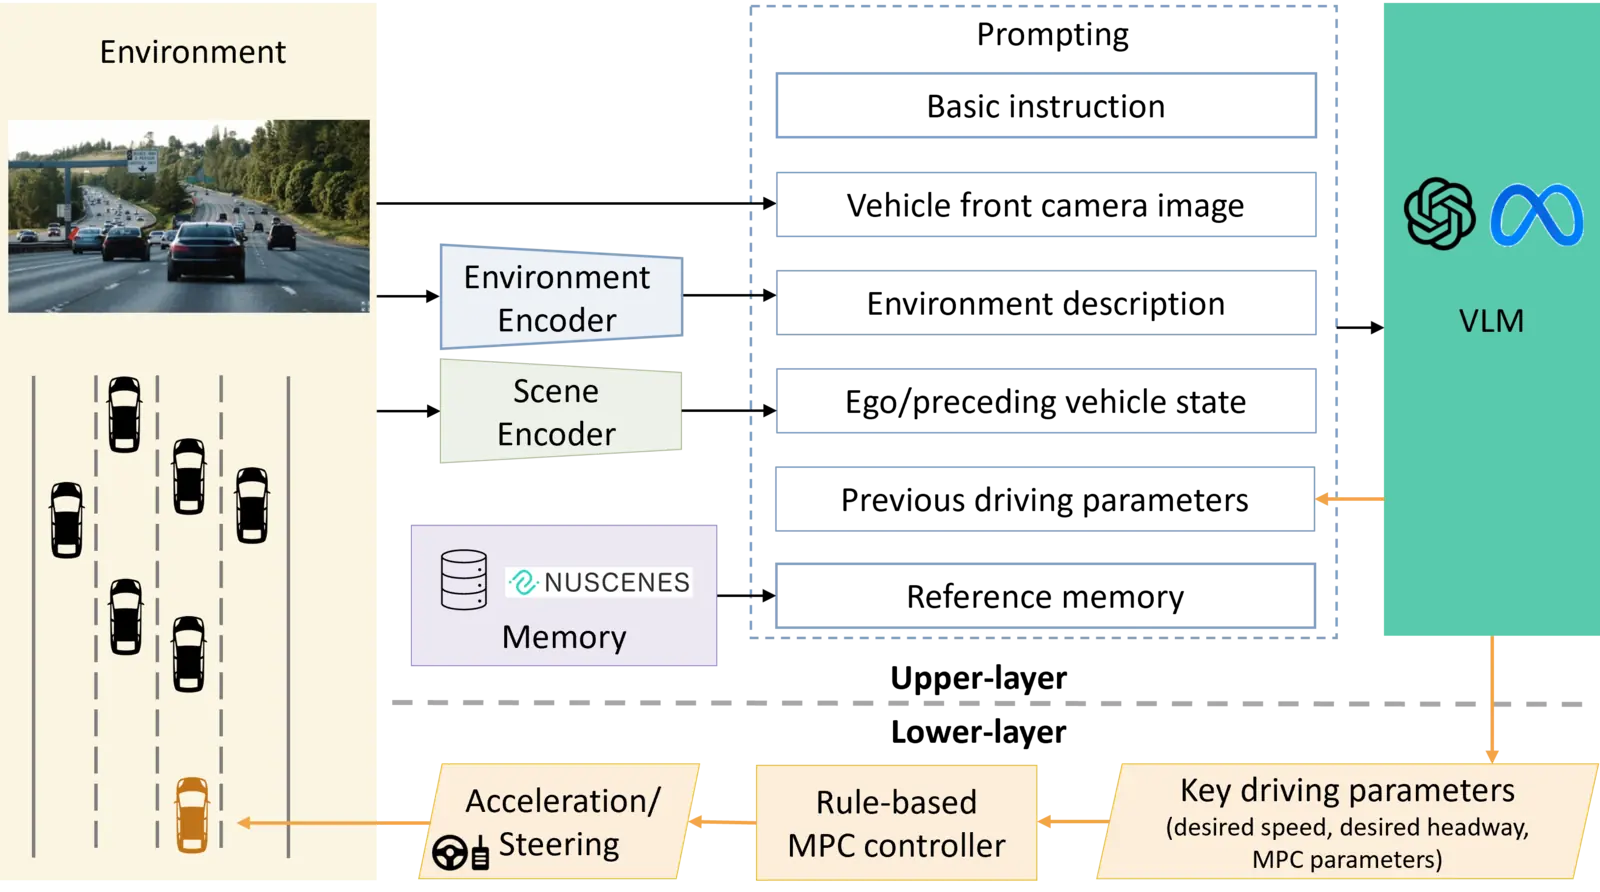
VLM-MPC: Vision Language Foundation Model (VLM)-Guided Model Predictive Controller (MPC) for Autonomous Driving

VLM-MPC: Vision Language Foundation Model (VLM)-Guided Model Predictive Controller (MPC) for Autonomous Driving

Long, K., Shi, H., Liu, J., & Li, X.

Transportation Research Part C. 2026

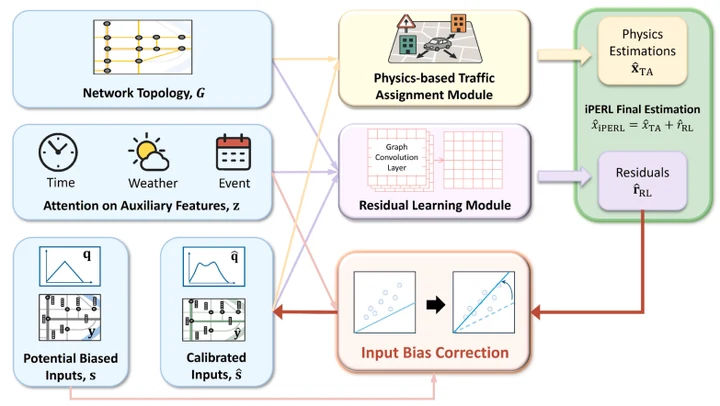
Iterative physics-enhanced residual learning for context-aware traffic assignment under biased inputs

Iterative physics-enhanced residual learning for context-aware traffic assignment under biased inputs

* Shi, Y., Long, K., Lam, W. H. K., Li, X., & Ma, W.

Transportation Research Part C. 2026

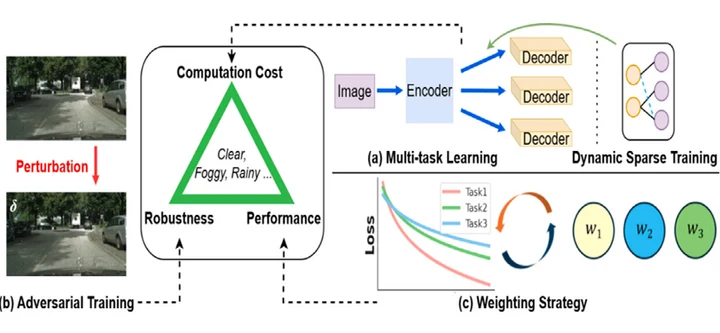
A Multi-task Sparse Adversarial Training framework for autonomous driving in harsh conditions

A Multi-task Sparse Adversarial Training framework for autonomous driving in harsh conditions

Guo, J., Cui, M., Yang, H., Long, K., Li, X., Qin, M., …, & Zhang, T.

Pattern Recognition. 2026

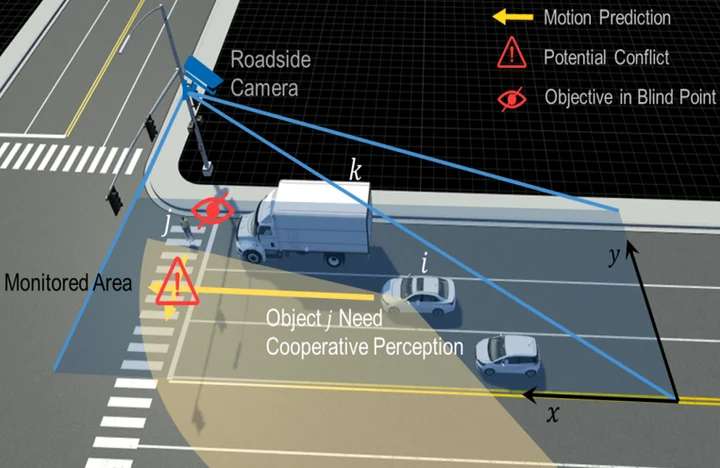
Real-time identification of cooperative perception necessity in road traffic scenarios

Real-time identification of cooperative perception necessity in road traffic scenarios

Ma, C., Li, H., Long, K., Zhou, H., Liang, Z., Li, P., Yu, H., & Li, X.

Transportation Research Part C. 2026

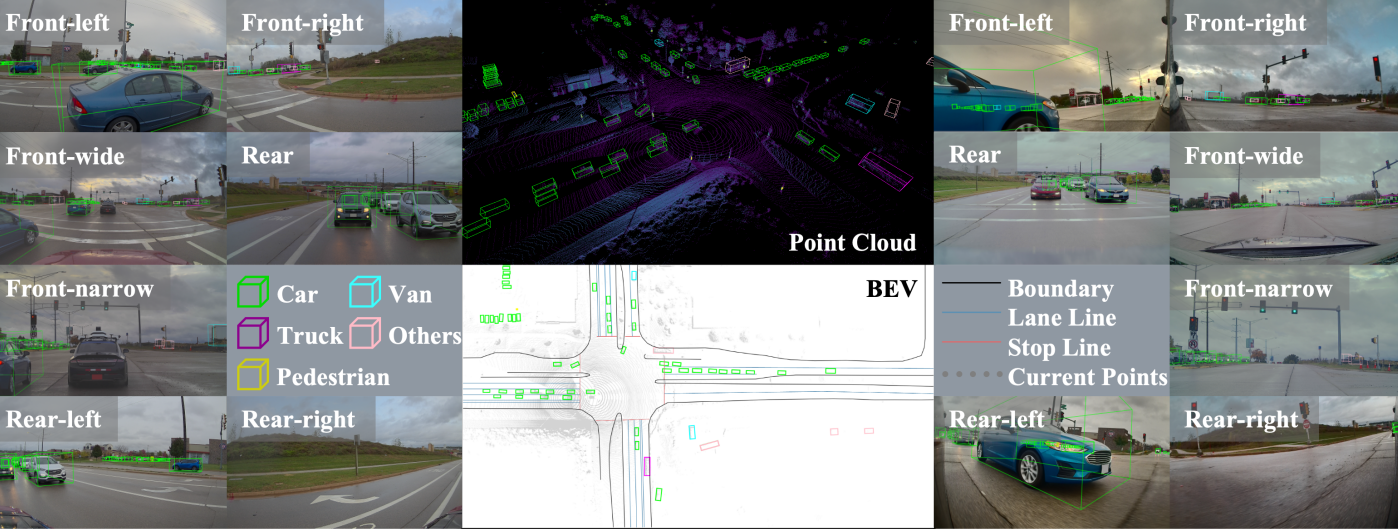
CATS-V2V: A real-world vehicle-to-vehicle cooperative perception dataset with complex adverse traffic scenarios

CATS-V2V: A real-world vehicle-to-vehicle cooperative perception dataset with complex adverse traffic scenarios

Li, H., Cao, B., Liang, Z., Li, W., Oh, J., Chen, Y., Liang, S., Zhou, H., Ma, C., Liu, J., Li, Z., Zhang, P., Long, K., …, & Li, X.

IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). 2026

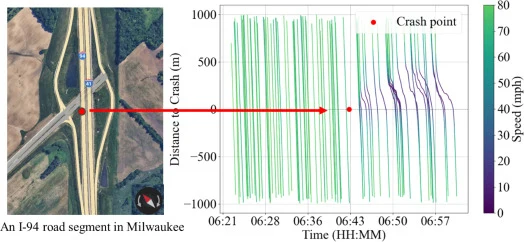
Real-time lane-level abnormal traffic detection on freeways using sparse telematics data

Real-time lane-level abnormal traffic detection on freeways using sparse telematics data

Liang, S., Ma, C., Li, P., Shi, H., Liu, J., Zhou, H., Long, K., Cao, B., Szymkowski, T., Shi, X., & Li, X.

Accident Analysis & Prevention. 2026

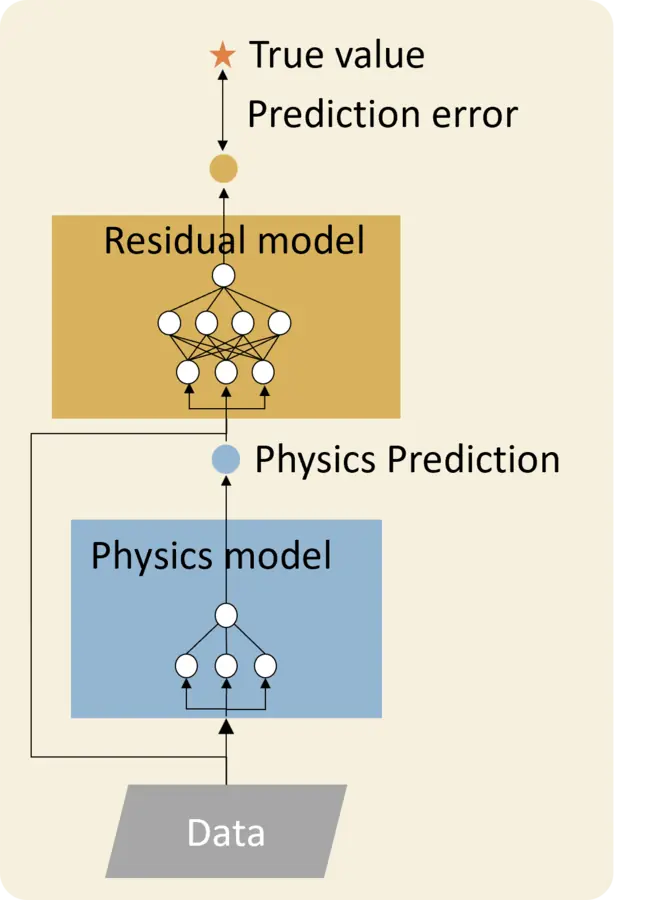
Physical enhanced residual learning (PERL) framework for vehicle trajectory prediction

Physical enhanced residual learning (PERL) framework for vehicle trajectory prediction

Long, K., Sheng, Z., Shi, H., Li, X., Chen, S., & Ahn, S.

Communications in Transportation Research. 2025
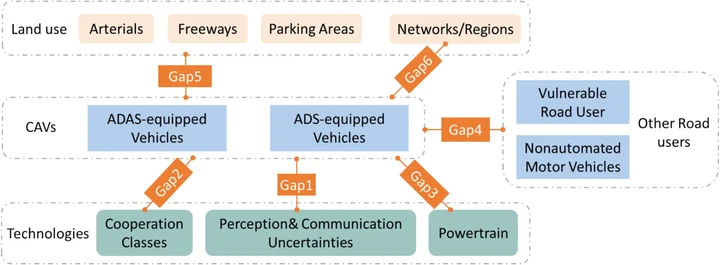
A Comprehensive Assessment of Connected and Automated Vehicle Analytical, Modeling, and Simulation Tools

A Comprehensive Assessment of Connected and Automated Vehicle Analytical, Modeling, and Simulation Tools

Long, K., Ma, K., Li, Q., Li, X., Huang, Z., James, R., & Ghiasi, A.

Transportation Research Part E. 2025

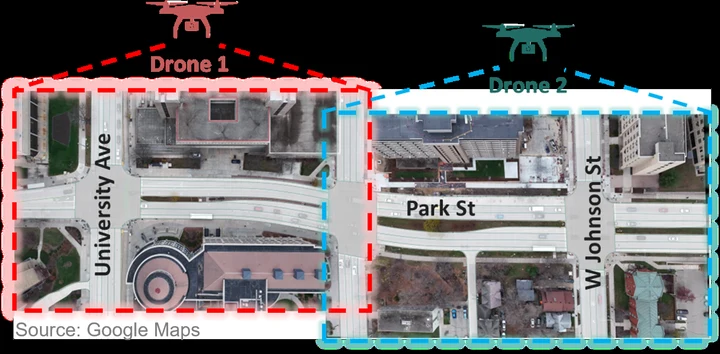
Urban vehicle trajectory dataset based on drone videos

Urban vehicle trajectory dataset based on drone videos

Long, K., Liang, Z., Zhou, H., & Li, X.

IEEE Intelligent Transportation Systems Magazine. 2025
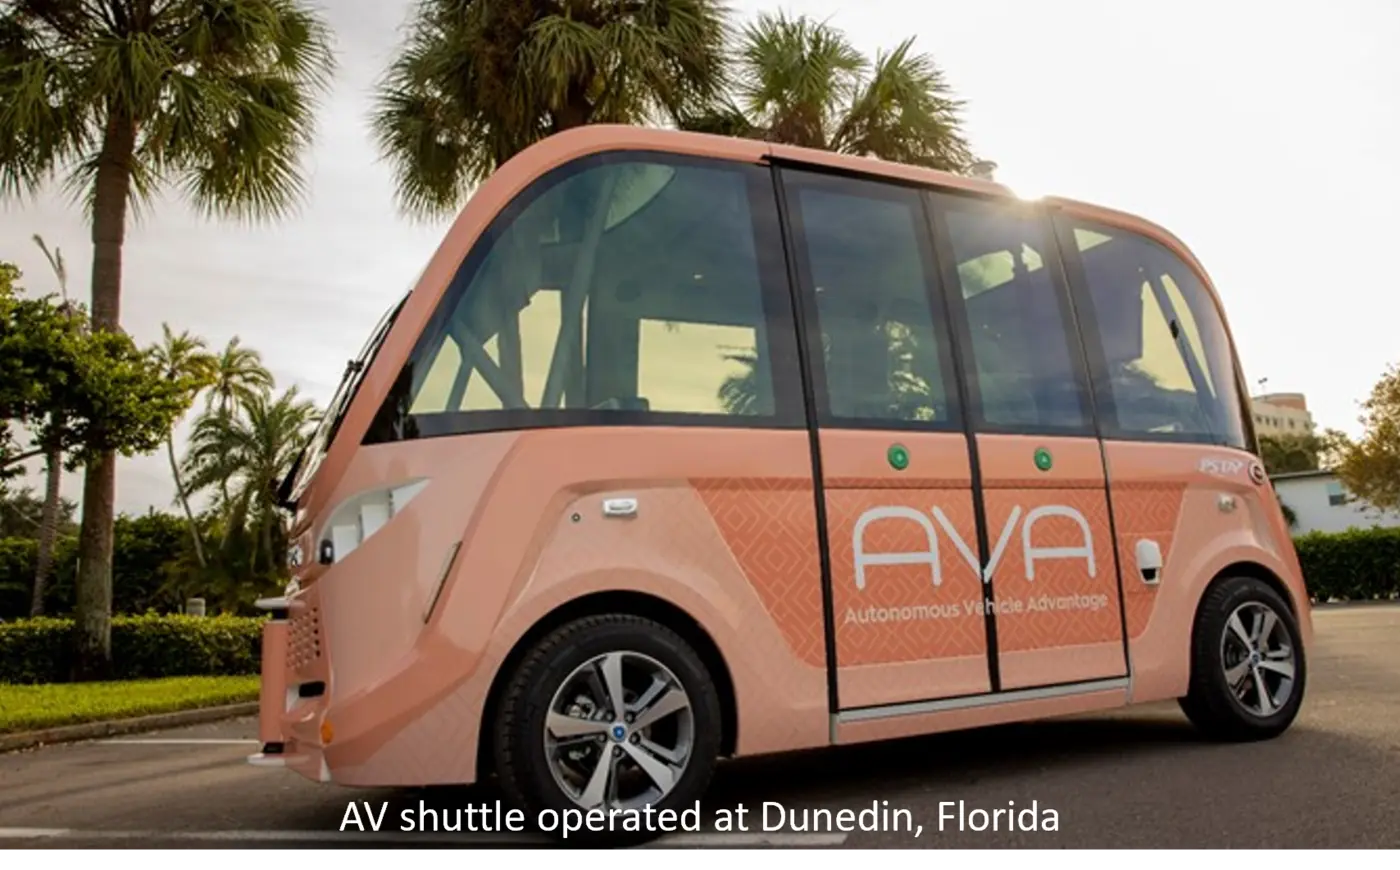
Before and after riding: changing comfort attitude towards autonomous shuttles from perspectives as riders, drivers, and pedestrians

Before and after riding: changing comfort attitude towards autonomous shuttles from perspectives as riders, drivers, and pedestrians

Long, K., Shi, X., Li, Y., Chen, Z., Wang, Y., & Li, X.

Transportation Research Part A. 2025

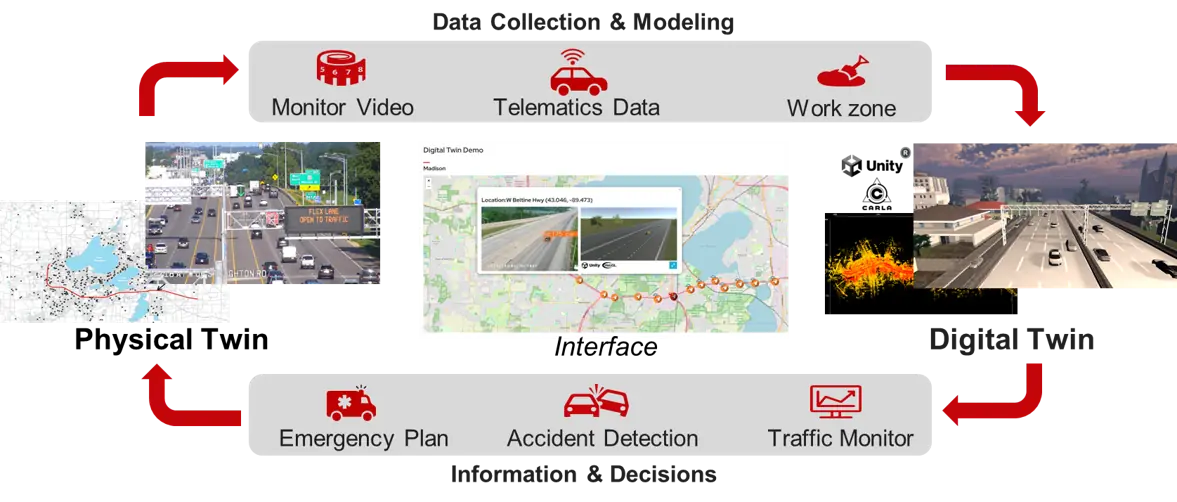
AI-Enabled Digital Twin Framework for Safe and Sustainable Intelligent Transportation

AI-Enabled Digital Twin Framework for Safe and Sustainable Intelligent Transportation

Long, K., Ma, C., Li, H., Li, Z., Huang, H., Shi, H., Huang, Z., Sheng, Z., Shi, L., Li, P., Chen, S., & Li, X.

Sustainability. 2025

Online Adaptive Platoon Control for Connected and Automated Vehicles via Physics Enhanced Residual Learning

Online Adaptive Platoon Control for Connected and Automated Vehicles via Physics Enhanced Residual Learning

Zhang, P., Huang, H., Zhou, H., Shi, H., Long, K., & Li, X.

Transportation Research Part C. 2025

An analytical eco-driving trajectory planning method with field test validation at intersections

An analytical eco-driving trajectory planning method with field test validation at intersections

Liang, Z., Ma, C., Zhou, H., Long, K., & Li, X.

Transportation Research Part D. 2025

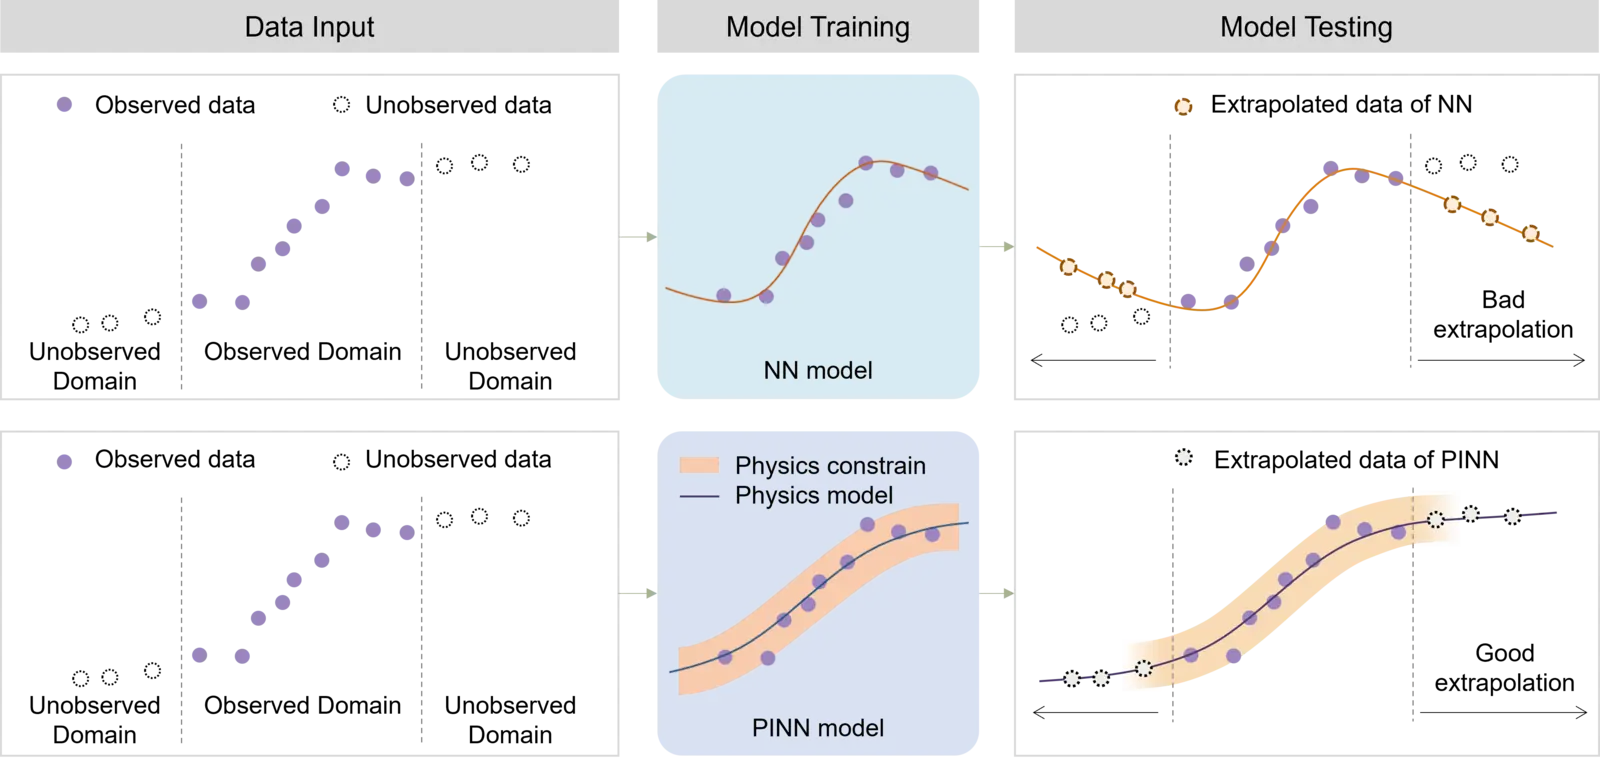
Physics-informed neural network for cross-dynamics vehicle trajectory stitching

Physics-informed neural network for cross-dynamics vehicle trajectory stitching

Long, K., Shi, X., & Li, X.

Transportation Research Part E. 2024

Traffic oscillations mitigation with physics-enhanced residual learning (PERL)-based predictive control

Traffic oscillations mitigation with physics-enhanced residual learning (PERL)-based predictive control

Long, K., Liang, Z., Shi, H., Shi, L., Chen, S., & Li, X.

Communications in Transportation Research. 2024

Full publication record on Google Scholar